Line Following Robot
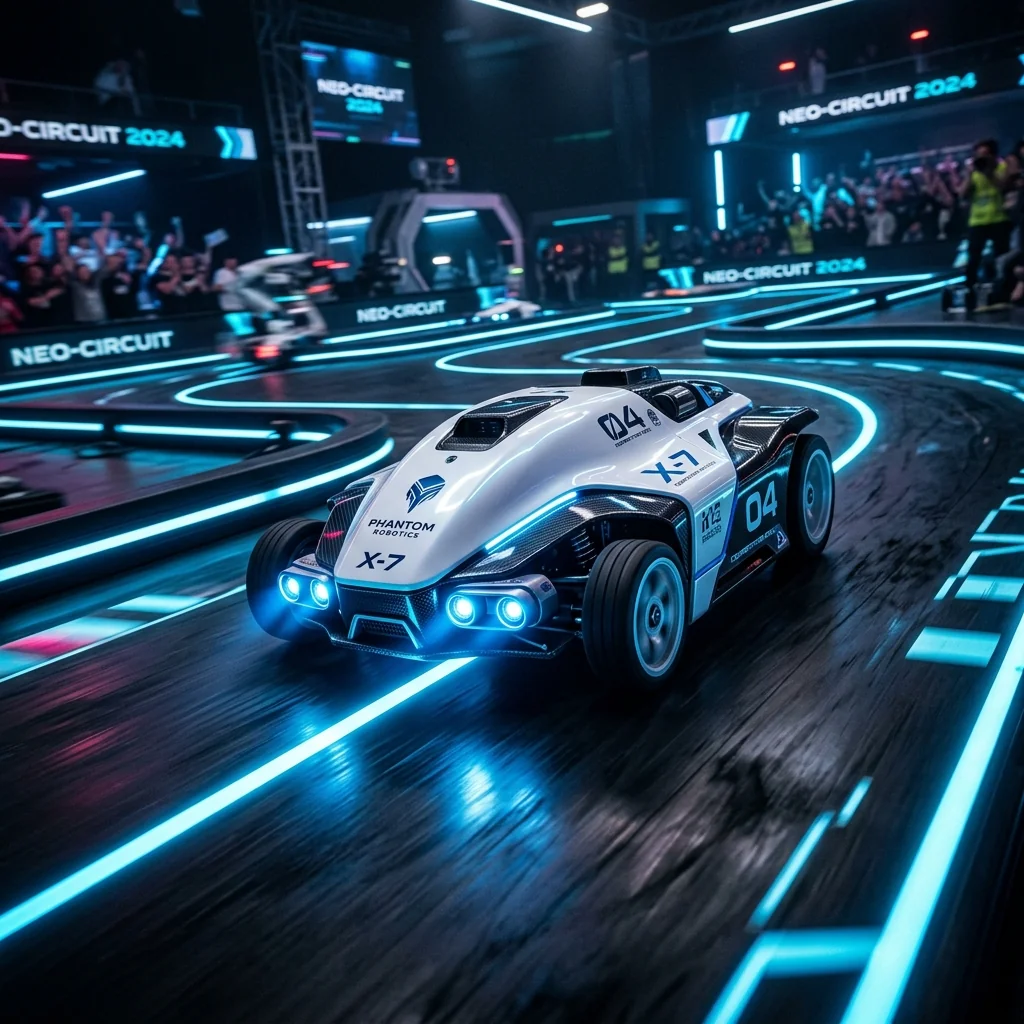
Project Overview
The Line Following Robot is an autonomous vehicle that navigates a predefined black-line track using an array of infrared (IR) sensors. Powered by an Arduino UNO and driven by dual DC gear motors, the robot uses a PID (Proportional-Integral-Derivative) control algorithm to maintain smooth, accurate path tracking even at higher speeds and around tight corners.
Key Features & Implementation
- 5-Sensor IR Array: Five IR sensors sample the track at 100Hz, providing high-resolution positional error data for the PID controller to compute steering corrections.
- PID Control Algorithm: A tuned PID loop dynamically adjusts left/right motor speeds to minimize deviation from the track centerline with minimal oscillation.
- Speed Optimization: The robot automatically slows down when approaching sharp curves (high error) and accelerates on straight sections for optimal lap times.
Challenges Solved
Tuning the PID constants (Kp, Ki, Kd) for stable tracking without oscillation required iterative manual testing. By implementing a real-time serial monitor readout and systematic Ziegler-Nichols tuning, optimal parameters were found that kept the robot on track even at maximum speed.
Explore Related Projects
Discover more of our robotics projects.
Smart Robotic Arm
Arduino-controlled 6-DOF robotic arm with servo motors for automated pick-and-place operations.
Automated Rover
A terrain-navigating rover with obstacle avoidance and remote control capabilities.