Bluetooth RC Car
Project Overview
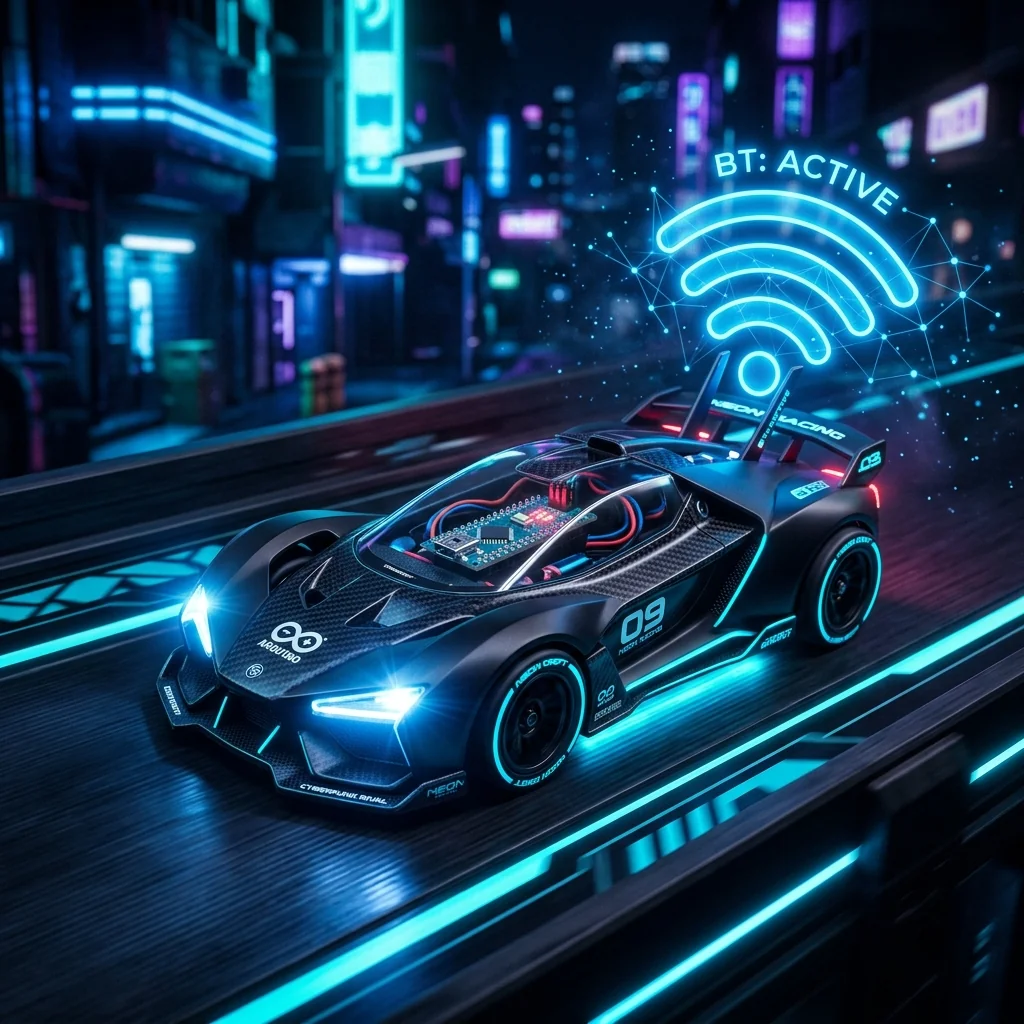
The Bluetooth RC Car is a four-wheeled robotic vehicle controlled wirelessly via Bluetooth using an HC-05 module paired with a custom-built Android controller app. Powered by an Arduino UNO and an L298N dual motor driver, the car supports real-time directional commands, variable speed control, and a horn feature — all transmitted over a stable 10-metre Bluetooth range.
Key Features & Implementation
- Wireless Bluetooth Control: The HC-05 module communicates with a smartphone over RFCOMM serial protocol, receiving single-character command packets at 9600 baud for near-zero latency response.
- Variable Speed with PWM: The L298N driver receives PWM signals from the Arduino, allowing smooth acceleration and deceleration curves rather than abrupt on/off motor switching.
- Custom Android App: A dedicated app built with MIT App Inventor provides a joystick-style interface for intuitive directional control and a turbo-boost button for max speed bursts.
Challenges Solved
Bluetooth signal drops caused erratic motor behaviour when the connection was momentarily lost. A watchdog timer was implemented on the Arduino that automatically halts all motors if no valid command packet is received within 300ms, ensuring the car never runs away uncontrolled.
Explore Related Projects
Discover more of our robotics and IoT projects.
Line Following Robot
Autonomous robot navigating black-line tracks using a 5-sensor IR array and real-time PID speed control.
Smart Robotic Arm
Arduino-controlled 6-DOF robotic arm with servo motors for automated pick-and-place operations.